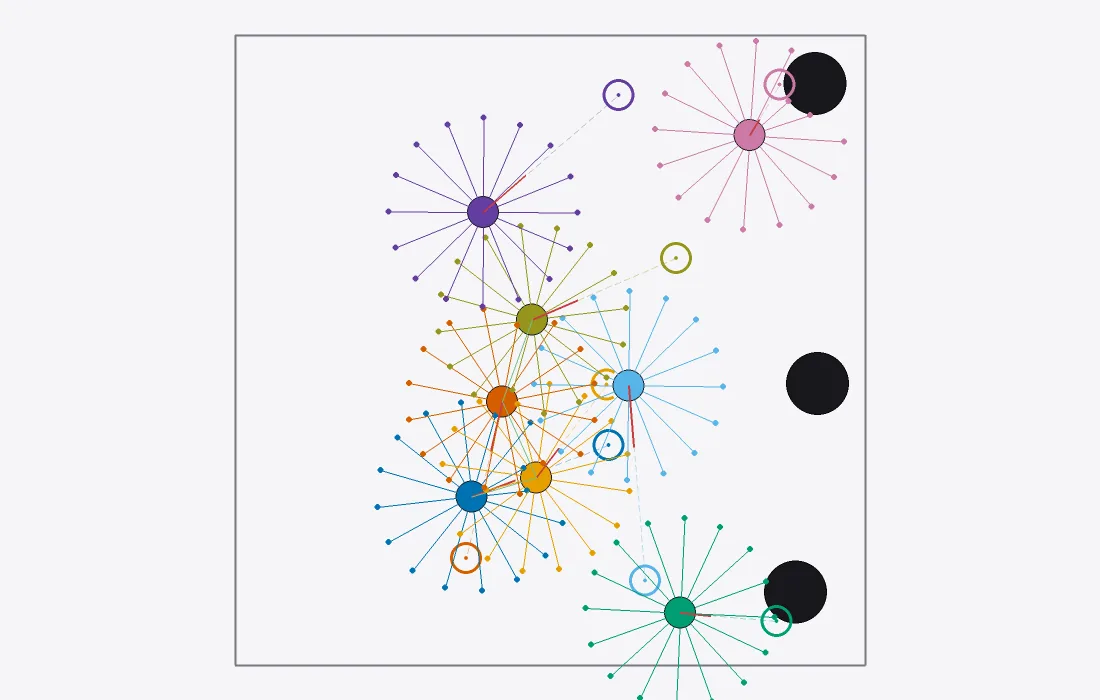
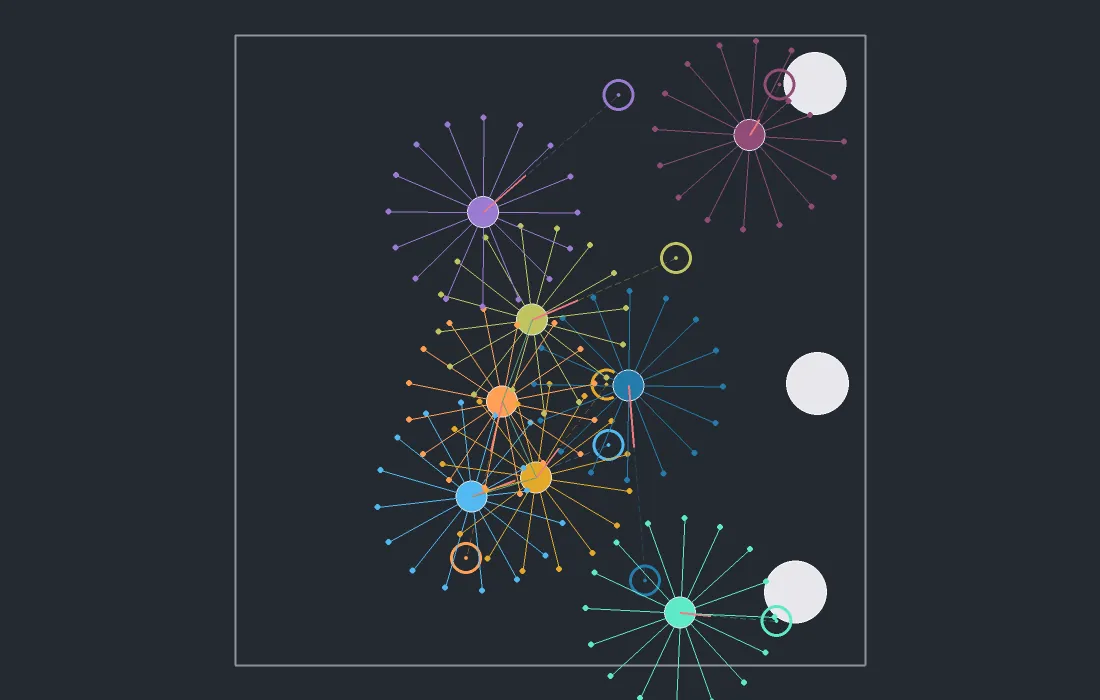
swarp: Swarm Simulation on NVIDIA Warp
WarpGPU-resident, differentiable, vectorized 2D multi-robot simulator with zero-copy PyTorch interop.
Robotics Engineer and Postdoctoral Researcher
Postdoc by day, robotics engineer by night. I work on planning and control of multi-robot systems and on legged locomotion, building algorithms that guarantee safety without sacrificing performance on real robots.
I like... robots, basketball, programming, gym, and sushi.

GPU-resident, differentiable, vectorized 2D multi-robot simulator with zero-copy PyTorch interop.
Model-based control for quadrupedal robots moving on compliant terrains.
Control of heterogeneous multi-robot fleet using hierarchical optimization and quadratic programming.
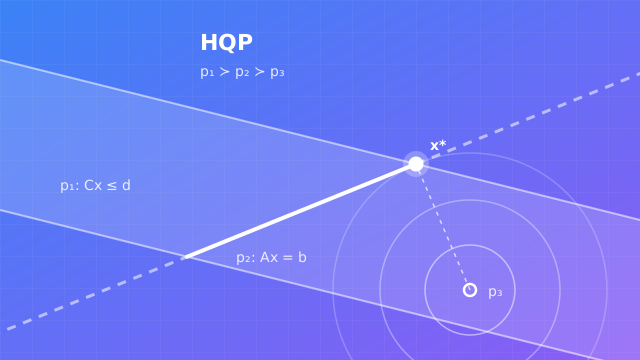
Python solver for strictly prioritized tasks with equality and inequality constraints. Installable with pip.
Control of multi-robot systems using reinforcement learning and JAX.
Docker container to be used with ROS 1 or ROS 2. Supports the usage of GUIs and NVIDIA GPUs.
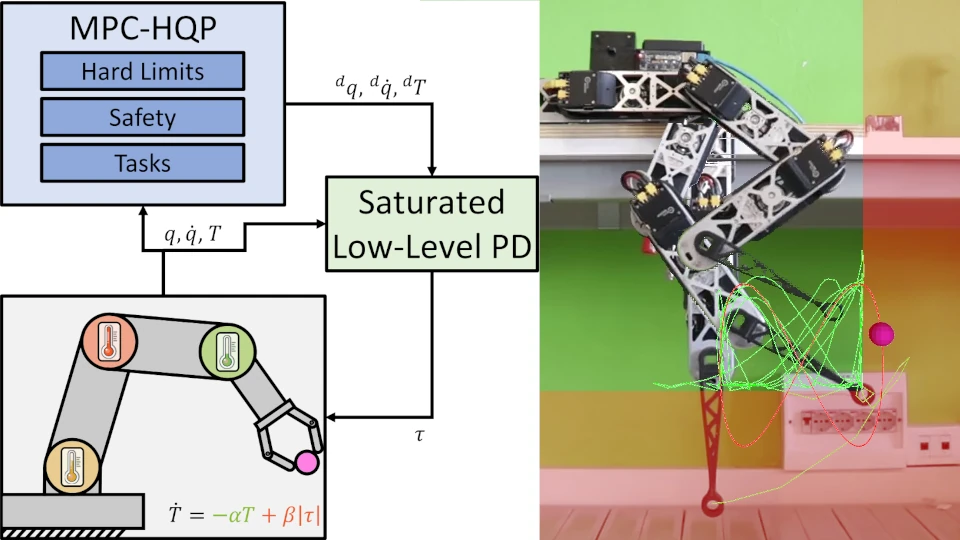
Hierarchical quadratic programming and MPC that fold motor driver temperature dynamics into the system model to prevent overheating.
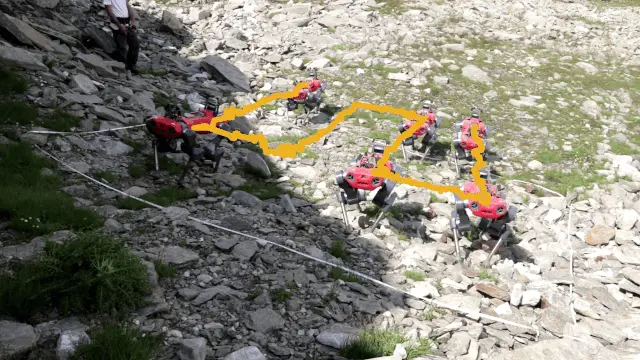
Autonomous monitoring framework for alpine screes using a quadrupedal robot equipped with cameras.
A labeled image dataset acquired by a quadrupedal robot for plant species detection across Annex I habitats of Italy.
Leverage hierarchical optimization (or hierarchical quadratic programming) for multi-robot coordination and guaranteed prioritized task execution.
A modular, replicable testbed, standardized protocol, and performance indicators to objectively benchmark legged locomotion over irregular and sloped terrains.