My Projects
Open-source code from my research on legged locomotion, hierarchical optimization and multi-robot control. Two of these repositories are the reference implementation of a peer-reviewed paper; the rest of the papers are on my publications page, and the matching slide decks are under talks and slides.
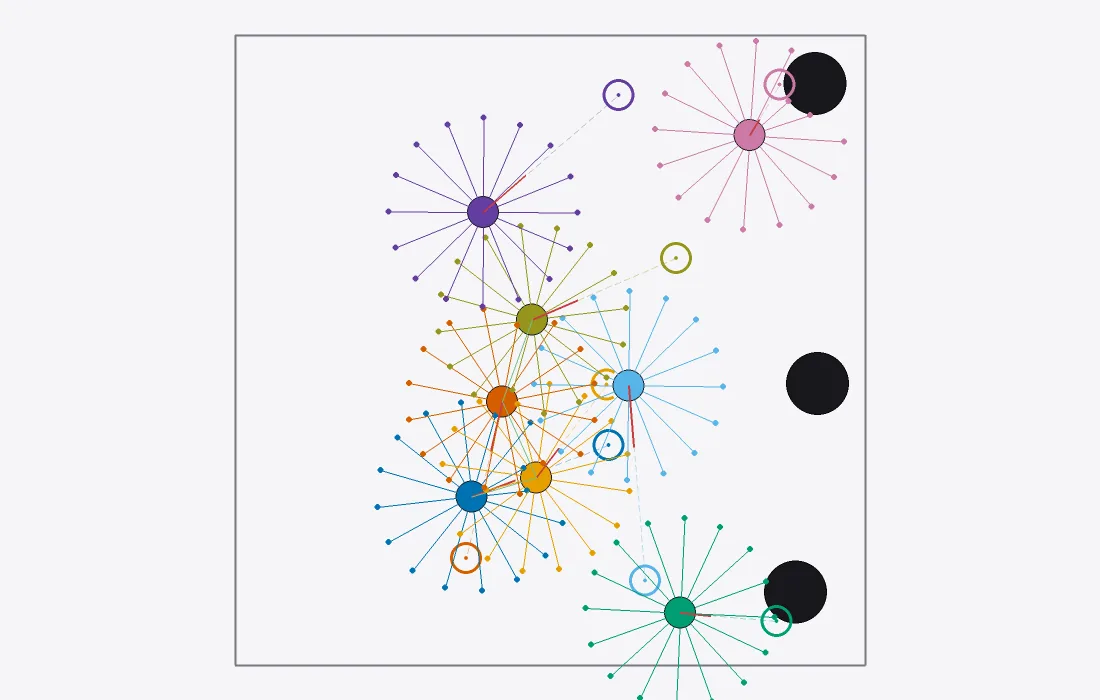
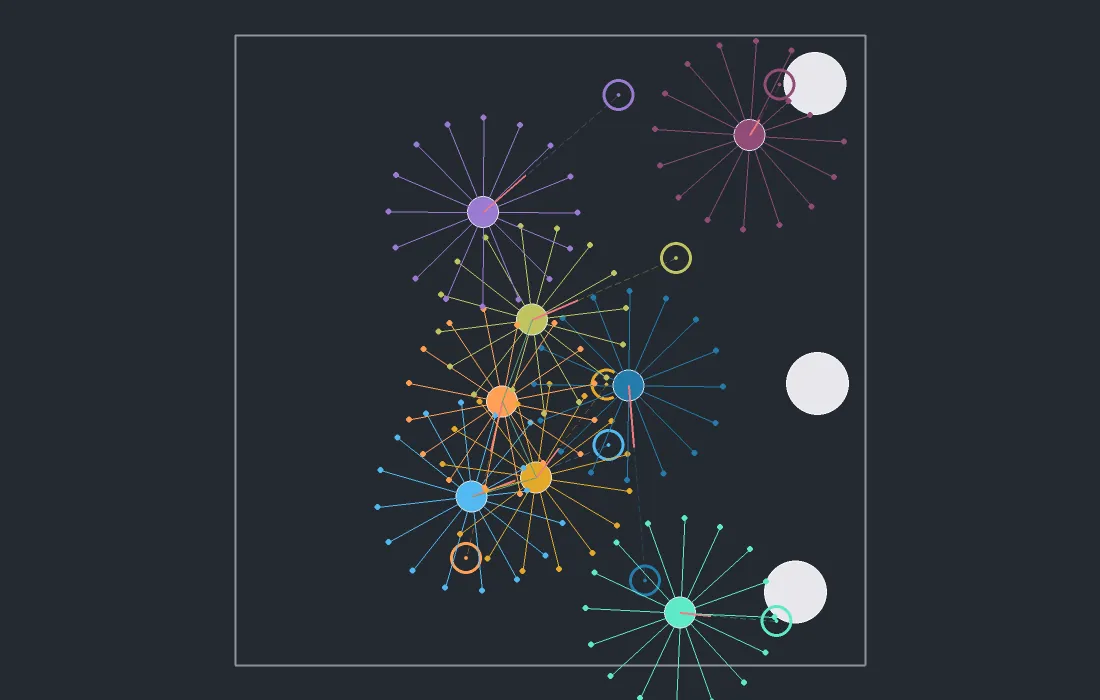
swarp: Swarm Simulation on NVIDIA WarpWarp
GPU-resident, differentiable, vectorized 2D multi-robot simulator with zero-copy PyTorch interop.
Control of Quadrupedal Robots on Soft Terrains
Model-based control for quadrupedal robots moving on compliant terrains.
Related paper: Soft Bilinear Inverted Pendulum: a Model to Enable Locomotion with Soft Contacts
Hierarchical Constraint-Based Control of Multi-Robot Systems
Control of heterogeneous multi-robot fleet using hierarchical optimization and quadratic programming.
Related paper: Managing Conflicting Tasks in Heterogeneous Multi-Robot Systems Through Hierarchical Optimization
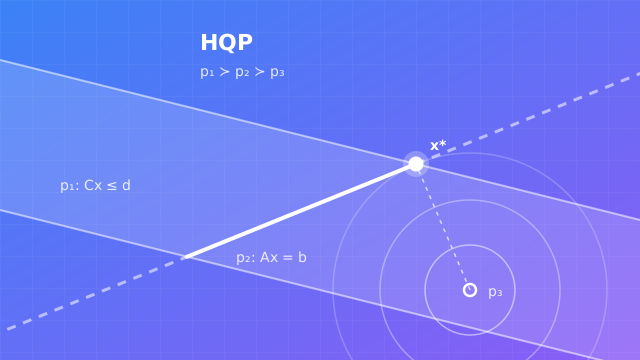
Hierarchical Quadratic Programming
Python solver for strictly prioritized tasks with equality and inequality constraints. Installable with pip.
Multi-Robot Systems Reinforcement LearningJAX
Control of multi-robot systems using reinforcement learning and JAX.
Docker Container for ROS (1 and 2), GUIs, and NVIDIA GPUsDocker
Docker container to be used with ROS 1 or ROS 2. Supports the usage of GUIs and NVIDIA GPUs.
UAV Sensor Fusion
Indirect Extended Sequential Kalman Filter for multi sensor fusion on UAVs.